INSTRUMENTATION · SENSOR FUSION · PROTECTION
Multi-Sensor Monitoring System for a Brushed DC Motor Driver
A monitoring system combining velocity, current, vibration, and temperature channels with sensor fusion, fan control, and a safety relay was verified in simulation.
Redundant monitoring instead of one measurement
The system was designed for one motor channel of a three-wheel mobile platform. The aim was not simply to measure speed, but to supervise velocity, current, vibration, and temperature together when an encoder fails or one sensing channel becomes noisy.
Four sensors, two protective outputs
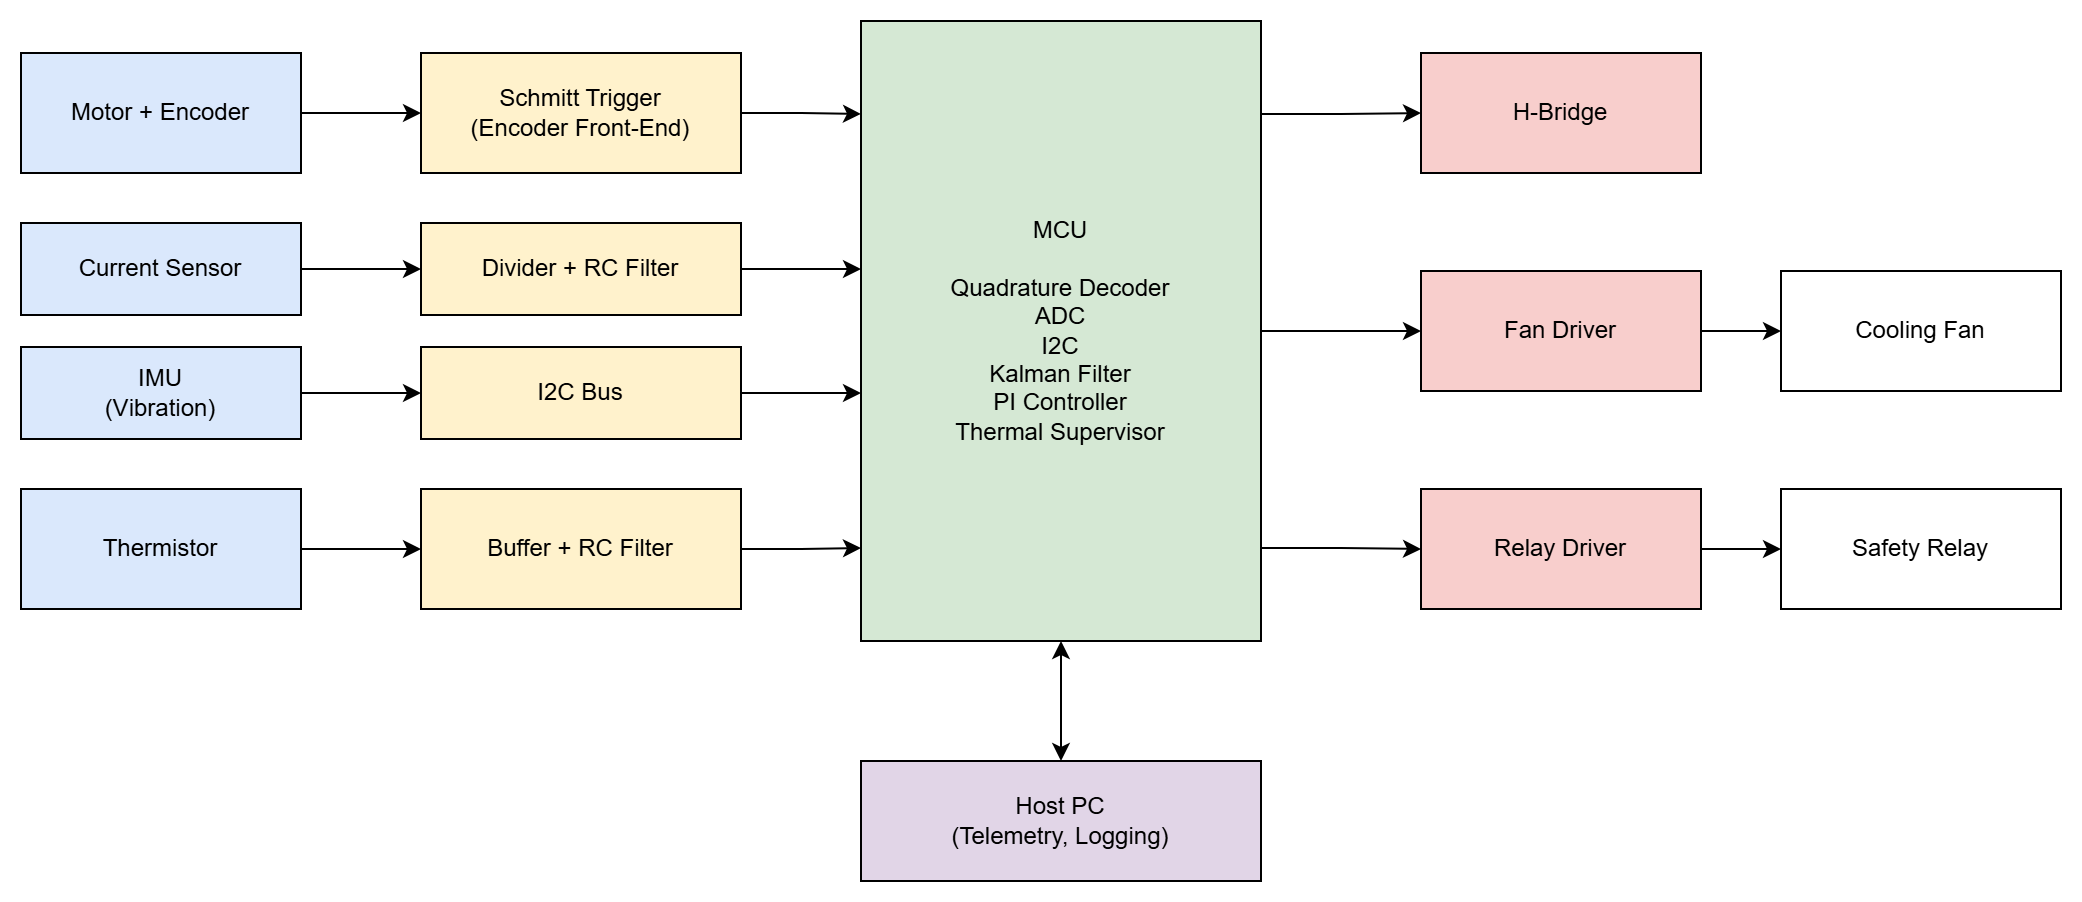
A quadrature encoder, ACS712 current sensor, MPU6050 IMU, and NTC thermistors feed an STM32G431-based acquisition layer. The DRV8874 motor driver, fan driver, and an SPDT safety relay that disconnects motor power are handled in the same monitoring chain. Analog channels are filtered and sampled through the 12-bit ADC, while vibration data arrives over I²C.
Velocity estimation and protection logic
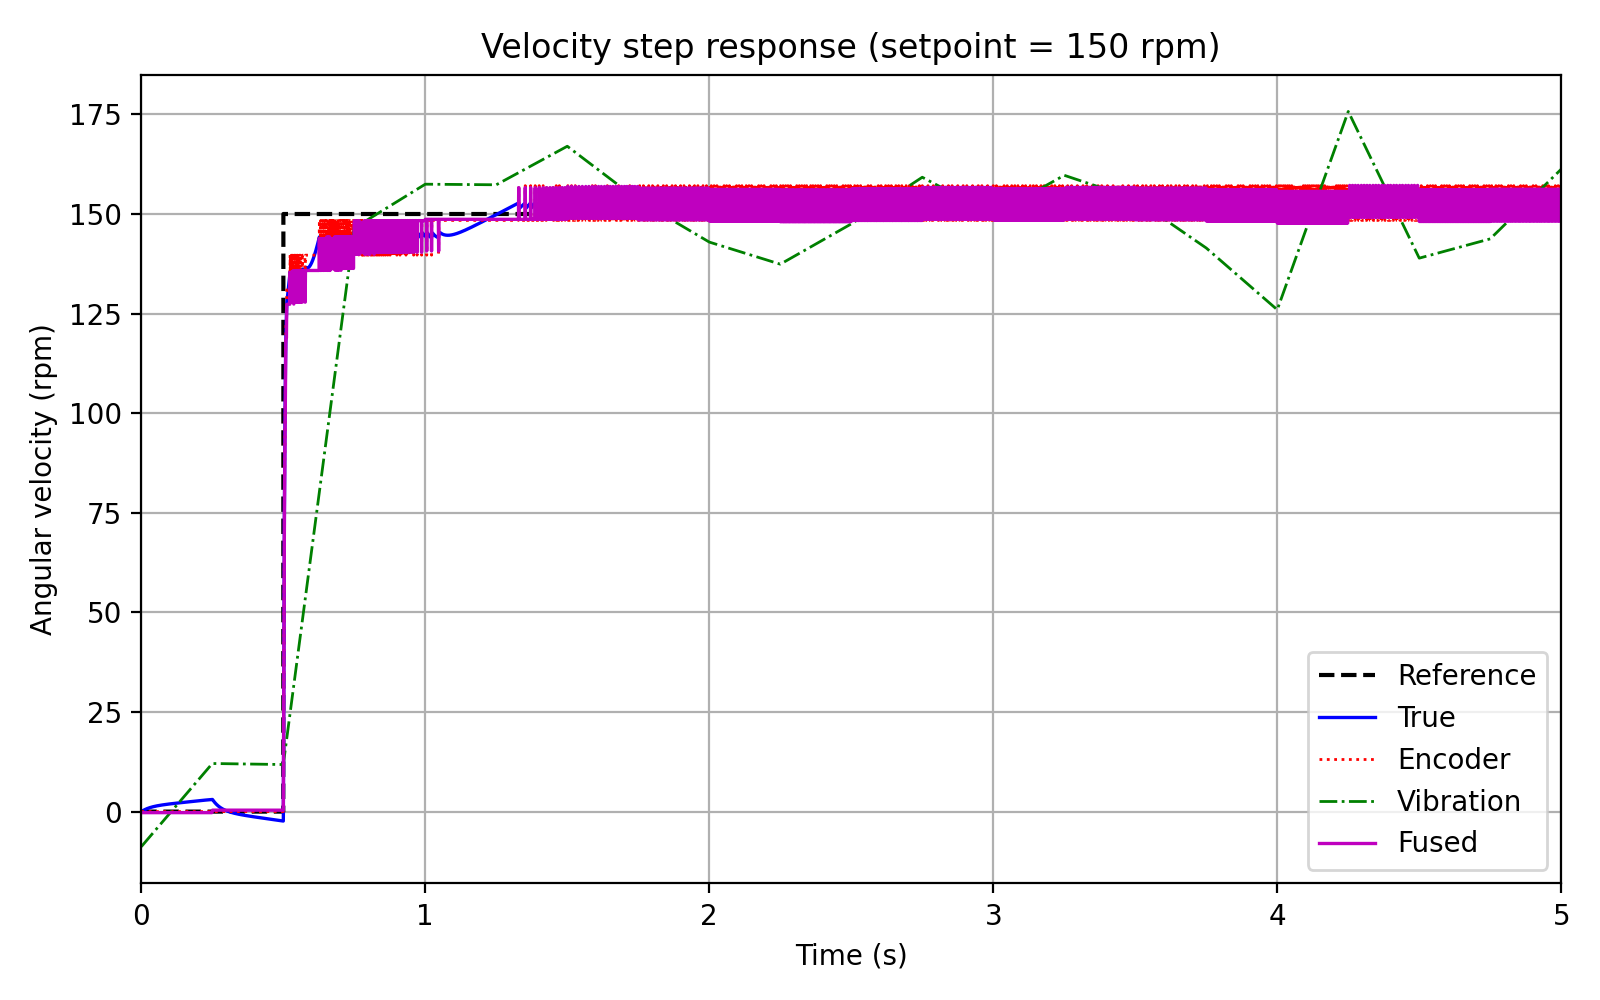
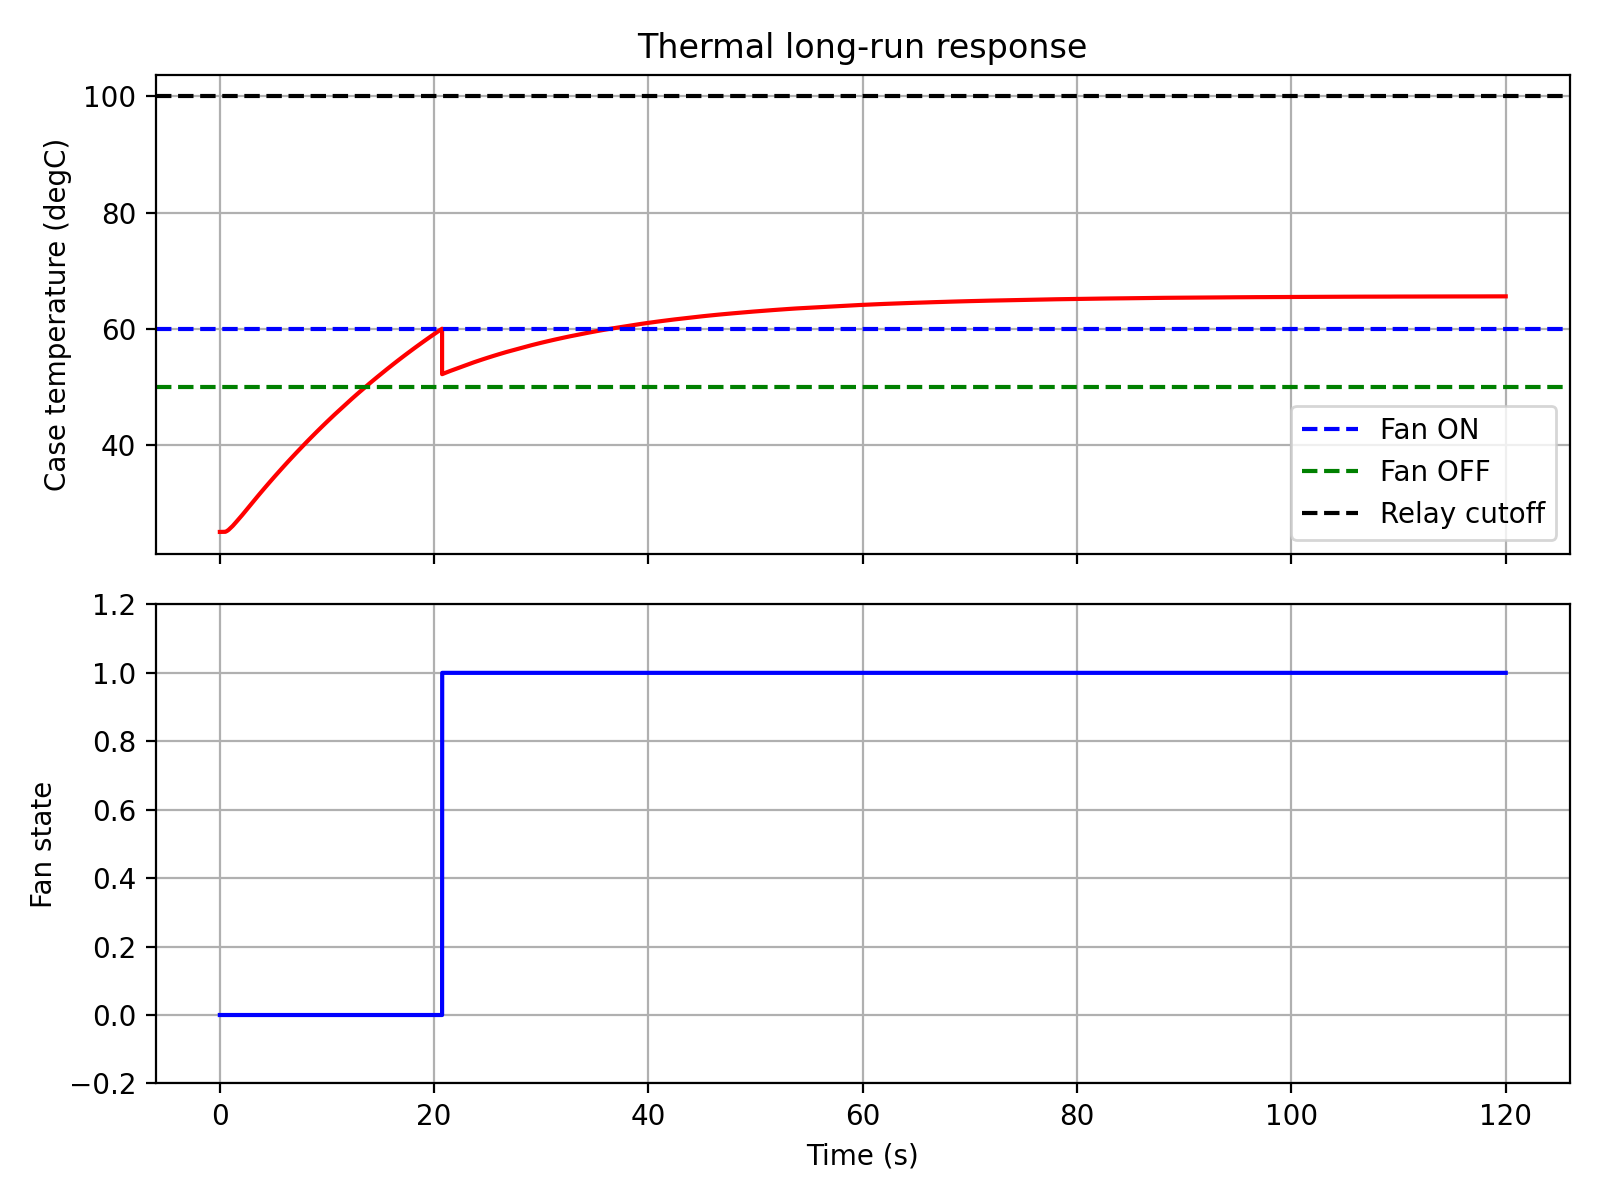
Encoder velocity and the estimate obtained from the vibration spectrum are combined with an inverse-variance weighted average. The main task runs at 1 kHz, while the vibration window is processed by FFT every 250 ms. The fan turns on above 60 °C and off below 50 °C; above 100 °C, the safety relay latches and disconnects motor power.
Verification across three environments
Analog conditioning and driver circuits were studied in LTspice, the motor-control and thermal model in MATLAB/Simulink, and statistical evaluation in Python. Across 600 runs, the fused velocity estimate reduced variance by 20.1% relative to the encoder and 94.6% relative to the vibration estimate. All of these results are simulation data.
Outcome and boundary
At the 150 rpm operating point, the model produced 2.09% overshoot and a 20.4 ms rise time. In the 120-second thermal run, case temperature settled near 65.6 °C with the fan active. The work tested the measurement chain and protection strategy quantitatively, but no physical prototype was built.